

PhD @GeorgiaTech | Robotics | CS https://teapawt.org/t.co/QzLezFDRkB
Atlanta, GA
Joined April 2009
- Tweets1.9K
- Following471
- Followers1.1K
- Likes3.5K


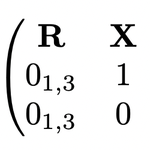


One of the side benefits of robot learning is that you no longer have to learn 50 different things to get something interesting working on a humanoid. Kinematics, RNEA, and RL/IL is the standard recipe these days.

Launching a new humanoid learning course at @CMU_Robotics in Spring 2027!
Every team will get its own (small) humanoid robot for hands-on labs.
Will open-source everything (lecture slides, codes). Stay tuned!

1
20
2,981
Hiring in robotics is so funny. I applied to @shieldaitech for a state estimation role, especially since the job description listed being familiar with libraries like GTSAM. You'd think I would be a great fit.
Got a rejection email in less than a week without any interviews. :)
Holy cow this is awesome! I have some nice application ideas if anyone is interested in collaborating.

I have more papers on Legged Robot State Estimation in the works so keep an eye on this space. :)


3
554
I've recently been seeing a lot of papers on legged robot proprioceptive state estimation compare against works that we outperform but not compare against ours.
arxiv.org/abs/2209.05644
Maybe this is because this paper was published during Covid and is lacking visibility?

It's strange because these papers are not comparing against the strongest baselines. And some of the cited works don't even have open source code available. This usually means readers might not be getting the full picture.
39
What a PhD from an acclaimed university gets you in 2026.
PhD grad: *does unique work in proprioception to stand out in robotics*
Employers that care about the research: Sorry we have a hiring freeze.
Every other employer: Yeah we want perception/vision experience - reject.
4
326
Varun Agrawal retweeted
Hidden deep within @GeorgiaTech is a lab filled with some of the most advanced experimental computers in the world.
This Rogues Gallery is a collection of early-stage novel computing systems that are helping shape the future.
Read more: cc.gatech.edu/external-news/…

ALT CRNCH Co-Director Hyesoon Kim, Rogues Gallery Director Jeff Young, and research technologist Will Powell in the Rogues Gallery.
This and also increased levels of frustration, impulsiveness and feelings of helplessness.

Pursuing a PhD took a significant toll on my mental health, particularly due to financial stress and uncertainty about my career future. This often made me less productive in my research, while promoting unhealthy work habits.
1
1
279
Trying to setup a basic webapp on @Azure and OMG, so many hidden steps and gotchas which the documentation doesn't address. Every time I think I've figured it out, I need to go back and enable some other service or extension.
This is the worst developer experience!
1
156
Using the zombie allegory from @siddhss5, the herd will definitely be coming here as well.
Between LLM, VGGT and 3DGS paper stacks, I don't know if I am looking forward to reading this new set unless I see something truly innovative or thought-provoking.

My prediction: we’re about to see hundreds of robotics papers built on SAM3D. Waiting for the first one to drop 👀
SAM3 & SAM3D from @metaai are just too good to be true!
1
307
Woah!

⚡️ Can one unified policy control 10 million different robots and zero-shot transfer to completely unseen robots, even humanoids?
🔗 Yes! Checkout our paper: arxiv.org/abs/2509.02815
If you are interested in massive multi-embodiment learning, come and chat with me at:
- Today, WS Sim-to-Real Transfer for Humanoid Robots @Humanoids2025
- Oct 20th, WS Foundation Models for Robotic Design @IROS2025
- Oct 24th, WS Reconfigurable Modular Robots @IROS2025

1
266
Varun Agrawal retweeted

There are currently 61 humanoid companies spanning 13 countries with a total of 88 humanoids
Spent my free time creating an extensive display of humanoid companies to learn the current landscape
Opinions:
- Super saturated, every developed country fund and build humanoid robots, even developing countries like Vietnam has their own humanoid.
- Software is the moat. Breakthrough in software will explode adaptation of robots in both consumer and industry.
Observation:
- Naming: Robots tends to be named in the following formula: Name + Generation (i.e. MagicBot Gen 1, Vanar Gen 1) or Name + Random Letter + Number (i.e. Jaka K1, Kinisi 01, Unitree G1).
- Two diversion in use case: One side focus on utility (Figure, X1, etc.), the other focus on companionship (Enchanted Tools, Andromeda, etc.)
Category imo:
- Unique Design: Fourier, Enchanted Tools, Slightly Overdone Robotics, Pollen Robotics.
- Unique Actuator: Clone Robotics
- Best Capabilities: too soon to tell, too much online cherry picked demos instead of real life demonstration.
- Most Natural Motion: Cartwheel Robotics, Pollen Robotics.
- Highest Cost: Tesla.
Hmu or comment below if you want the list.
Varun Agrawal retweeted

arxiv.org/pdf/2509.16469
A Framework for Optimal Ankle Design of Humanoid Robots
Ankle design can get optimized, and there are some trade-offs.


Varun Agrawal retweeted

Probably nothing, but multiple devices recorded video of a venue, then sent that to the @AukiNetwork's growing number of community nodes, that then collaborated to stitch it all together into this 3D map of the venue...
Collaborative data capture. Collaborative reconstruction.
