

The Business of Robotics and Physical AI. Research & Podcast. https://teapawt.org/t.co/aanMm8guOj
Joined June 2026
- Tweets51
- Following21
- Followers240
- Likes9


Pinned Tweet
Core Matter studies the business of Physical AI.
We publish research on robotics costs, supply chains and deployment, plus interviews with the people building the stack.
Follow for research, charts and interview clips.
Start here in the reply.
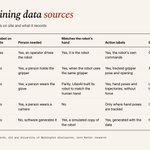
Robot training data is moving from robots to people to software.
The cost of an hour of training data now depends on where it comes from:
• 𝗥𝗼𝗯𝗼𝘁𝘀 𝗰𝗮𝗺𝗲 𝗳𝗶𝗿𝘀𝘁. In 2022, Google's RT-1 took 13 robots and 17 months to collect 130,000 demonstrations.
• 𝗧𝗲𝗹𝗲𝗼𝗽𝗲𝗿𝗮𝘁𝗶𝗼𝗻 𝗶𝘀 𝗻𝗼𝘄 𝘀𝗼𝗹𝗱 𝗯𝘆 𝘁𝗵𝗲 𝗵𝗼𝘂𝗿. Chinese data factories sell robot teleoperation data at Rmb500 to Rmb1,000 ($70 to $141) per hour.
• 𝗣𝗲𝗼𝗽𝗹𝗲 𝘄𝗶𝘁𝗵 𝗵𝗮𝗻𝗱𝗵𝗲𝗹𝗱 𝗴𝗿𝗶𝗽𝗽𝗲𝗿𝘀 𝗮𝗿𝗲 𝗳𝗮𝘀𝘁𝗲𝗿. Japan's AIRoA had 179 people record 8,434 hours in a little over 2 months, with no robots involved.
• 𝗛𝘂𝗺𝗮𝗻 𝘃𝗶𝗱𝗲𝗼 𝗶𝘀 𝗰𝗵𝗲𝗮𝗽𝗲𝗿 𝘀𝘁𝗶𝗹𝗹. Mercor pays businesses $12 to $18 per approved hour of workplace footage, and @NVIDIARobotics' GR00T 2 trained on 402,730 hours of human video.
• 𝗦𝗶𝗺𝘂𝗹𝗮𝘁𝗶𝗼𝗻 𝗰𝗼𝘀𝘁𝘀 𝘁𝗵𝗲 𝗹𝗲𝗮𝘀𝘁. The @allen_ai MolmoB0T team estimates $2 to $5 per hour of simulated robot data.
Robot teleoperation was about 5% of GR00T 2's pretraining hours.


The robot AI stack is splitting in two. CoRL 2026 showed it clearly.
(1) A planner decides what to do, and (2) a fast model, the actor, does the hands-on work.
@OpenAI's GPT-6 Astra planned while @nvidia's GR00T 2 handled the manipulation, and the pair succeeded in 97 to 98 of 100 toy assembly trials. @GoogleDeepMind used the same split on Mercedes-Benz lines.
5 key takeaways from CoRL 2026:
1. The planner layer is getting cheaper. Luma AI's open 27bn-parameter model matched Astra at $0.29 per task, against $4.87.
2. Training data is getting cheaper. GR00T 2 trained on about 92% human video and about 5% robot teleoperation.
3. How the motion is recorded matters more than raw hours. In LiberAI's test, 10,000 hours of glove recordings beat 2mn hours of web video.
4. Deployment data compounds. Russ Tedrake called mid-training data "commoditized" and said deployment data is something "you have to earn."
5. Touch is the next frontier. @robbyant_brain open-sourced LingBot-Touch, a tactile model pretrained on nearly 5,000 hours of real tactile data.
Full #CoRL2026 recap on @CoreMatter_: read.corematter.com/p/corl-2…

1
43
Robots are being built in 3 layers, and each layer works on a different clock.
Tsinghua professor Hang Zhao, co-founder of Galaxea, described this framework in his CoRL 2026 keynote, and @NVIDIARobotics built GR00T 2 the same way.
• 𝗦𝘆𝘀𝘁𝗲𝗺 𝟮 𝗽𝗹𝗮𝗻𝘀 𝗼𝘃𝗲𝗿 𝘀𝗲𝗰𝗼𝗻𝗱𝘀 𝘁𝗼 𝗺𝗶𝗻𝘂𝘁𝗲𝘀. @OpenAI's GPT-6 Astra and @GoogleDeepMind's Gemini Robotics-ER work at this layer.
• 𝗦𝘆𝘀𝘁𝗲𝗺 𝟭 𝗵𝗮𝗻𝗱𝗹𝗲𝘀 𝗱𝗲𝘅𝘁𝗲𝗿𝗶𝘁𝘆, 𝘁𝗿𝗮𝗰𝗸𝗶𝗻𝗴 𝘁𝗵𝗲 𝗵𝗮𝗻𝗱 𝗮𝗻𝗱 𝘁𝗵𝗲 𝗼𝗯𝗷𝗲𝗰𝘁 𝘁𝗲𝗻𝘀 𝗼𝗳 𝘁𝗶𝗺𝗲𝘀 𝗽𝗲𝗿 𝘀𝗲𝗰𝗼𝗻𝗱. VLAs and world action models such as GR00T 2 compete here.
• 𝗦𝘆𝘀𝘁𝗲𝗺 𝟬 𝗿𝗲𝗮𝗰𝘁𝘀 𝘁𝗼 𝗰𝗼𝗻𝘁𝗮𝗰𝘁 𝗮𝗻𝗱 𝗳𝗼𝗿𝗰𝗲 𝗵𝘂𝗻𝗱𝗿𝗲𝗱𝘀 𝗼𝗳 𝘁𝗶𝗺𝗲𝘀 𝗽𝗲𝗿 𝘀𝗲𝗰𝗼𝗻𝗱. NVIDIA's SONIC whole-body controller sits here.
• 𝗡𝗩𝗜𝗗𝗜𝗔'𝘀 𝘀𝘁𝗮𝗰𝗸 𝘀𝗵𝗼𝘄𝘀 𝘁𝗵𝗲 𝗰𝗹𝗼𝗰𝗸𝘀. GR00T 2 Turbo plans 1.6 seconds of motion about once a second on a Jetson AGX Thor, and SONIC sets joint targets 50 times a second.
• 𝗦𝗽𝗲𝗲𝗱 𝗰𝗵𝗮𝗻𝗴𝗲𝘀 𝘁𝗵𝗲 𝗿𝗲𝘀𝘂𝗹𝘁𝘀. In Zhao's simulated kitchen test, 4 approaches completed over 60% of tasks when thinking time was free. Once thinking time counted toward a 50-second deadline, a policy calling a frontier model completed 15%.
Roboticist Benjie Holson called System 1 "the big challenge for robotics in the next 6 months."

The robot AI stack is splitting in two. CoRL 2026 showed it clearly.
(1) A planner decides what to do, and (2) a fast model, the actor, does the hands-on work.
@OpenAI's GPT-6 Astra planned while @nvidia's GR00T 2 handled the manipulation, and the pair succeeded in 97 to 98 of 100 toy assembly trials. @GoogleDeepMind used the same split on Mercedes-Benz lines.
5 key takeaways from CoRL 2026:
1. The planner layer is getting cheaper. Luma AI's open 27bn-parameter model matched Astra at $0.29 per task, against $4.87.
2. Training data is getting cheaper. GR00T 2 trained on about 92% human video and about 5% robot teleoperation.
3. How the motion is recorded matters more than raw hours. In LiberAI's test, 10,000 hours of glove recordings beat 2mn hours of web video.
4. Deployment data compounds. Russ Tedrake called mid-training data "commoditized" and said deployment data is something "you have to earn."
5. Touch is the next frontier. @robbyant_brain open-sourced LingBot-Touch, a tactile model pretrained on nearly 5,000 hours of real tactile data.
Full #CoRL2026 recap on @CoreMatter_: read.corematter.com/p/corl-2…
Gift guide curated for the robotics and physical AI community. Let us know which ones are your favorites!
The holidays are around the corner. Inspired by @lennysan, I'm releasing the first Core Matter Holiday Gift Guide!
The list is tailored for the hardware builders, the robot deployers, the Physical AI-curious software engineers, parents with kids who love robots, and even your suppliers in Shenzhen.
It ranges from $20,000 to $14. From practical, professional tools, to wellness, delightful things that bring a smile to my face.
Thanks to everyone who replied to the polls, including @alexembodied, @darthur, @benbeerengineer, @dcsan, @liminalsunset_, @TouficJrab, @boxcardavid, @_baldtires, @MikeAHFerguson, @Joyingeth, @RohitSatyaV, @reticente07, @LiamTal and @lasermatts.
No affiliate links, so I'm not benefiting from recommending these products.
Full guide here: read.corematter.com/p/roboti…

56
Core Matter retweeted

The holidays are around the corner. Inspired by @lennysan, I'm releasing the first Core Matter Holiday Gift Guide!
The list is tailored for the hardware builders, the robot deployers, the Physical AI-curious software engineers, parents with kids who love robots, and even your suppliers in Shenzhen.
It ranges from $20,000 to $14. From practical, professional tools, to wellness, delightful things that bring a smile to my face.
Thanks to everyone who replied to the polls, including @alexembodied, @darthur, @benbeerengineer, @dcsan, @liminalsunset_, @TouficJrab, @boxcardavid, @_baldtires, @MikeAHFerguson, @Joyingeth, @RohitSatyaV, @reticente07, @LiamTal and @lasermatts.
No affiliate links, so I'm not benefiting from recommending these products.
Full guide here: read.corematter.com/p/roboti…
When you watch @Tesla Optimus handle an object, look at how the thumb meets the fingers and what keeps the grasp stable.
Prensilia (@prensilia) Managing Director Francesco Clemente offers a crash course in how hand designers work backward from everyday tasks:
- Start with the grasp. A cylindrical grip, a pinch grip and a lateral grip use the hand differently.
- Study which grasps people use. Francesco describes looking at grasp taxonomies to understand the hand shapes needed in daily activities.
- Design around the task. The useful set of movements depends on the work the hand needs to perform.
- Consider manufacturing complexity. A hand with many motors can perform many movements, but Francesco explains why scaling that design becomes difficult.
- Choose coverage deliberately. Prensilia studies how a simpler mechanism can cover commonly used grasps while keeping cost and complexity manageable.
Watch Prensilia’s managing director explain how those choices shape a robot hand.
107
Following @1x_tech’s NEO and the push toward robots in the home?
In San Francisco, people can pay $60 for two @taurobots robots to clean their home for an hour.
During a @CoreMatter_ visit:
- They completed about 80% of one floor. Tasks included tidying, wiping surfaces, vacuuming, mopping and cleaning the toilet.
- Each robot had a remote human operator. Staff also handled delivery and pickup.
- Delicate tasks took more time. Moving objects to clean underneath them and handling soft items were difficult.
- Batteries needed swapping after about an hour. A longer booking would need a plan for that turnaround.
- The visit also supplied training data. Data collection was accepted as part of the booking to help train the robots.
Would you let robots clean your home?

2
116
Building hardware at @Apple and ordering your first small production run are different jobs.
Seeed Studio (@seeedstudio) founder Eric Pan (@256ericpan) describes what changes when experienced corporate hardware teams become startup founders:
- Order volume changes the relationship. A startup may bring demanding specifications while placing a small order with a small supplier.
- Corporate methods need adapting. Eric describes founders with @Apple or @Microsoft experience discovering that the approach from their former employer does not fit the new situation.
- Collaboration becomes central. He encourages a more agile, relationship-based way of working with manufacturers, with room to discuss constraints and adjust together.
- Requirements need context. The question is what this supplier can deliver for this product at this volume, with the resources available.
For a founder making that transition, which part of your manufacturing approach would you change first?
Watch Seeed Studio’s founder explain the shift.
1
84

A farm machine carrying 18 desktop computers caught Bonsai Robotics (@bonsairobotics) CEO Tyler Niday (@niday_tyler)’s attention.
The machine came from Blue River Technology, which later became part of John Deere (@JohnDeere).
Reflecting on his early work at Blue River, he recalls:
- A specific job: the tractor thinned lettuce while moving through the field, with the computers mounted on its back.
- A later computing platform: the team used @nvidia’s TX1 with YOLO-based deep learning as its work evolved.
- A practical perception problem: distinguishing green weeds from green crops so the machine could tell them apart.
Watch Bonsai Robotics’ cofounder recount the work.
1
1
75
Full conversation with Tyler Niday, CEO of Bonsai Robotics: youtu.be/EeLUwoukj8g
58
A humanoid’s knee and wrist need different actuator properties. They perform different jobs inside the same robot.
Our actuator graphic maps typical choices across joint groups.
- Legs manage changing loads and repeated ground contact.
- Wrists need precision within limited packaging space.
- Weight near the arm’s end adds another design constraint.
Start with the joint’s job, then examine its actuator. The graphic shows typical trade-offs across designs.

2
2
91

Manufacturing speed starts before a factory builds the product.
Eric Pan, Seeed Studio’s founder, describes the surrounding network. Hardware teams face trade-offs between quality, cost and lead time. They also need access to people and specialized capabilities.
- Engineers bring the skills needed for the project.
- Suppliers provide the components and capabilities it requires.
- Their responsiveness helps the team move as requirements change.
Pan describes that combination in Shenzhen’s manufacturing network. Finding the right capabilities is part of getting hardware built.
Watch the full conversation: youtu.be/2hTEse2n7Dg
Subscribe to YouTube channel: youtube.com/@CoreMatterLabs
3
142
A robot hand contains several businesses inside one product.
Complete-hand manufacturers bring together components from several technical disciplines. Our July supply-chain graphic separates those layers.
- Actuation supplies motion through motors and related components.
- Transmission carries that motion through the hand’s mechanisms.
- Sensors provide information about movement and contact.
- Control electronics use that feedback to coordinate movement.
The map highlights component opportunities alongside complete-hand companies. Its company examples reflect the July primer.

1
57
Read full article: read.corematter.com/p/dexter…
Subscribe to newsletter: corematter.substack.com

14
A transparent cup can confuse a robot’s depth camera. Its depth map can contain very little usable information.
Shan Luo explains how touch helps fill that gap. He studies robotic perception at King’s College London.
- Vision identifies sparse cues, such as the cup’s rim.
- Those cues guide where the robot makes contact.
- Touch checks the edges and helps estimate the cup’s position.
In these experiments, vision guides touch before the grasp. Contact gives the robot information that vision struggles to provide.
1
25
Watch the full conversation: youtu.be/zORIEuxs9_Q
Subscribe to YouTube channel: youtube.com/@CoreMatterLabs

Holding a tool and inserting a connector require different grasps.
A hand’s specifications make more sense alongside its task. Our dexterous-hands guide connects familiar jobs with relevant properties.
- Tool holding brings sustained grip and heat into focus.
- Connector insertion brings positioning repeatability into focus.
- Object shape and movement help determine the required grasp.
The attached graphic connects those tasks with hand specifications.
Start with what the hand needs to do. Then compare the properties that support that job.

1
2
67
Read full article: read.corematter.com/p/dexter…
Subscribe to newsletter: corematter.substack.com
15