

Empowering AI Evolution Ecosystem
Palo Alto, CA
Joined August 2024
- Tweets158
- Following78
- Followers461
- Likes207




🙌 This work is built in collaboration with Berkeley RDI, alongside researchers from UC Santa Cruz, UC Santa Barbara, UW-Madison, MIT, the University of Toronto, Johns Hopkins, CMU, Purdue, and Texas A&M.
At 2077AI, we build open benchmarks that show both what frontier models can do and where they fall short. In that spirit, CyberArena’s engine, challenges and match replays are all open source.
Read more:
📄 Paper: arxiv.org/abs/2610.19005
🌐 Homepage: cyber-arena.ai
🤗 Leaderboard: huggingface.co/spaces/2077AI…
💻 GitHub: github.com/cyber-arena-ai/cy…

Can agents organize without centralized control?
In EoM, agents bid to act, earn from useful work, and go bankrupt when ineffective. Across 5 domains, specialist workflows emerge.
Co-authored by researchers from Harvard, MIT, the Kempner Institute + 2077AI.
zhentingqi.github.io/interna…

Leonard Read's pencil story: no one knows how to make a pencil from scratch, yet millions are made without a central manager. Each worker knows only their part. Incentives, not central control, coordinate their efforts.
Current multi-agent AI seems to work the opposite way. A central manager does everything: assigns roles, writes the workflow, and decides who acts next. As agents increase and tasks get harder, that manager might become the bottleneck: it should understand every agent and every task, and adaptation becomes inefficient.
So how can a group of machine agents organize themselves into something none of them could achieve alone? Further, how can that society of agents keep improving itself over time?
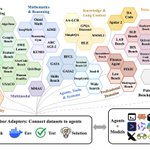
In Economy of Minds (EoM), we show that simple local incentives can drive global self-coordination and self-improvement for modern LLM agents. We let agents live in a minimal economy: they compete for work, earn by helping others succeed, and go broke when they don't. Workflows, specialists, and improvement naturally emerge, with no one in charge.
Across 5 domains (math reasoning, financial research, scientific research, accelerator design, and distributed-system optimization), limited agents grow into strong societies.
The whole idea in a 90-second cartoon👇
Limits: one robot platform, four tasks, 20 trials each.
Explore TouchScale 👇
📄 Paper: arxiv.org/abs/2610.10288
🤗 Dataset: huggingface.co/datasets/2077…
💻 Code: github.com/phai-lab/touchsca…
🌐 Project: touch-scale.github.io
📝 Blog: 2077ai.com/research/touchsca…

TouchScale is a project co-led by researchers at Texas A&M University and 2077AI together with 14 collaborating institutions.
Huge thanks to @EdisonLeeROC, @haohw_, Qianqian Yang, Zihao Zhu, @ZihanWang123, @Neutrino_l, @zhiwen_fan_ and all contributors who helped build it.