

The world's open robotics lab. Apply now.
bitrobot.ai
Joined November 2024
- Tweets1.6K
- Following1.8K
- Followers11K
- Likes4.6K





BitRobot 🦾 retweeted

Special Shoutout to our friends in @anvil_robotics @AGIBOTofficial @MeckaAI @xdofai @robocurve @cortexairobot @makermodsai @GenrobotAI @eastworlds_io @BitRobotNetwork @ScaleAILabs @LeRobotHF @huggingface @roborobots @ROBOTIS for helping us with our early beta testing across Asia, Europe, and the Americas Europe and America 🌍.
A truly global stress test of Dream-1 before our launch!

BitRobot 🦾 retweeted

A really cool competition that pushes the frontier of what's possible in embodied ai. This is a really hard task -- paper is unforgiving -- and no one nailed it but substantial progress was made. Excited to see what people can do next year

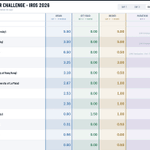
The first ever Origami Challenge with @SharpaRobotics at @ieeeiros IROS 2026 concluded.
We asked teams to fold a paper airplane to test policies in dexterous manipulation.
14 global teams made it to the final round. Here are the results ↓
BitRobot 🦾 retweeted

A simple paper airplane. A serious challenge for robotic dexterity. ✈️🤖
Proud to team up with @BitRobotNetwork for the first-ever Origami Challenge at #IROS2026.
Huge congratulations to all 14 finalist teams! Excited to see how far we can push the boundaries of dexterous manipulation together.
The first ever Origami Challenge with @SharpaRobotics at @ieeeiros IROS 2026 concluded.
We asked teams to fold a paper airplane to test policies in dexterous manipulation.
14 global teams made it to the final round. Here are the results ↓
BitRobot 🦾 retweeted

Super accurate SLAM on @BitRobotNetwork RoboCap.
Congrats to the @GroundedSI team...keep cooking!

BitRobot 🦾 retweeted
Sooo cool!

I wanted to share something I've been working towards since forever. I've finally built out a full slam + hand reconstruction pipeline that works IN REAL TIME at 30fps on a single rockchip 3588. All streaming directly to @rerundotio from a @BitRobotNetwork robocap. This is similar to what a Quest3 or Project Aria 2 provides, but opensource 🙂
I'm so excited I finally don't have to really on closed source software like the meta quest or others. I finally have a realtime performant pipeline that works on an edge computer, but importantly can also scale to a high performance one when needed.
BitRobot 🦾 retweeted

I wanted to share something I've been working towards since forever. I've finally built out a full slam + hand reconstruction pipeline that works IN REAL TIME at 30fps on a single rockchip 3588. All streaming directly to @rerundotio from a @BitRobotNetwork robocap. This is similar to what a Quest3 or Project Aria 2 provides, but opensource 🙂
I'm so excited I finally don't have to really on closed source software like the meta quest or others. I finally have a realtime performant pipeline that works on an edge computer, but importantly can also scale to a high performance one when needed.
As I'm working on finding more datasets to test my pipeline, I found a really cool one from Meta. This is Show3D and it does ego + exo data capture on a mobile capture rig, its focused on hand/object interaction in the willd.
I've so far registered it to the @rerundotio OSS catalog, but I think I found a few issues. The tracking confidence is more unstable then I would expect and the object often has low tracking confidence on large swaths of of the segment.
I'll spend more time on it and see if its a me error, or something with the data labels.
Also sadly, they only provide the stereo images, no IMU =/
BitRobot 🦾 retweeted

Oragami folding is quite an interesting benchmark test for robotic dexterous manipulation because it really challenges both the limits of hardware and AI model capabilities. Here they are using robot hand from @SharpaRobotics. I also learned from @micoolcho that there’s people in Japan that can fold a tiny crane as small as your finger tips all based on tactile and joint position with no vision at all. If robots can do that one day, then we know dexterous manipulation has been solved. Very impressive to see how much these teams can do in such short amount of time. Definitely not easy. Thanks @dabblerer_ for the tour! #IROS2026
BitRobot 🦾 retweeted

Long-horizon, contact-rich tasks like furniture assembly are a demanding benchmark for embodied AI.
@BitRobotNetwork is putting autonomous humanoid loco-manipulation to the test.
1/ Nobody has benchmarked a humanoid on autonomous IKEA furniture assembly before.
Today at @ieeeiros 2026, the first attempts begin.
It’s a test of autonomous loco-manipulation: long-horizon sequencing, precise coordination, contact, force, recovery, and movement ↓

BitRobot 🦾 retweeted
One simple fold for robot, one giant flight for robotkind.
Everyone was clapping when the robot finally did it 👏
Come check out Robotic Origami Challenege if u r here at IROS2026 !

BitRobot 🦾 retweeted

Packed room at our office launch last Friday!
Builders from Physical Intelligence, Google DeepMind, Tesla, Anthropic, Dyna + beyond explored the full human data stack we’re building, from capture hardware to enrichment to training-ready outputs.
GSI was built to plug easily into the training flows teams already use.
BitRobot 🦾 retweeted
Looks like our @frodobots Earth Rover Mini got an intelligence upgrade from Muse!

BitRobot 🦾 retweeted
We’re building human-centric robotics from the data layer up, the missing piece for generalist robots.
RoboCap + Grounded API turn raw human action into metric 3D labels ready for training.
The hardware and the tooling have always been fragmented. We built them as one stack ↓

BitRobot 🦾 retweeted

Great way to scale real world data for humanoid robotics
The only way that LLM scaling laws apply is if there is enough data, and this is how you solve the data bottleneck
Congratulations @micoolcho and team!!
1/ Better robot models come from better data.
That takes two things: hardware that captures it fully, and tooling that turns it into training signal.
We built the first. Today, @GroundedSI launches the second: Grounded API. Access both hardware + API ↓
BitRobot 🦾 retweeted

RoboCaps — foundational data for robotics 🧢
1/ Better robot models come from better data.
That takes two things: hardware that captures it fully, and tooling that turns it into training signal.
We built the first. Today, @GroundedSI launches the second: Grounded API. Access both hardware + API ↓
BitRobot 🦾 retweeted
Great ego data at scale requires hand tracking to succeed in difficult in-the-wild scenarios, not just in carefully collected settings.
Here are some examples of our hand tracking in the tricky long-tail:
BitRobot 🦾 retweeted
Ever since Project Aria came out, I wanted a similar experience that wasn't gatekept by Meta. These guys are doing it. The hardware is legit and API works.
Worth giving them a look!
Grounded API is live.
- SOTA on hand-tracking benchmarks (< 1 cm)
- SOTA on SLAM benchmarks
- In-the-wild ego data -> enriched data in minutes
- Integration with @huggingface @LeRobotHF & @rerundotio
- Built for @BitRobotNetwork RoboCap suite
Technical report & more↓
BitRobot 🦾 retweeted

Egocentric data is more usable when it’s enriched - and available in formats the community can train on.
GroundedAPI from @GroundedSI turns raw RoboCap video + IMU into millimeter-fidelity 3D motion data, exportable in LeRobot format (Parquet + MP4) and Hub-ready.
Excited to see more large-scale, real-world ego datasets land on the Hub with this release📷
Grounded API is live.
- SOTA on hand-tracking benchmarks (< 1 cm)
- SOTA on SLAM benchmarks
- In-the-wild ego data -> enriched data in minutes
- Integration with @huggingface @LeRobotHF & @rerundotio
- Built for @BitRobotNetwork RoboCap suite
Technical report & more↓
BitRobot 🦾 retweeted
12k RoboCap units sold to-date.
There'll be millions of hours of ego data collected on RoboCap by our customers/partners and @BitRobotNetwork
1/ Better robot models come from better data.
That takes two things: hardware that captures it fully, and tooling that turns it into training signal.
We built the first. Today, @GroundedSI launches the second: Grounded API. Access both hardware + API ↓