

Ph.D. student at the intersection of robotics, controls, and ML at UC San Diego
San Diego
Joined July 2020
- Tweets21
- Following243
- Followers131
- Likes626


Pinned Tweet
🚨New exciting work: arxiv.org/abs/2204.12507 with @SylviaLHerbert
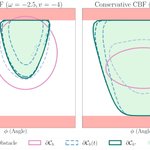
We propose a simple yet powerful method to refine approximately valid CBFs (e.g. neural CBFs) using dynamic programming based reachability analysis, to guarantee safety.
(1/n) 🧵👇

With many of my colleagues we are at the picket lines to force UC to stop negotiating in bad faith. We are merely asking for a stipend that covers basic living expenses in CA.
Check fairucnow.org/ to see our demands and what you can do in solidarity #FairUCNow

Breaking News: Academic workers across the University of California system walked off the job on Monday as part of a strike over pay and benefits. nyti.ms/3g5d5cy

Traveling with the Shinkansen from Tokyo to Kyoto today omw to @iros2022 with @thomas__lew. If you’re working on safety and active learning in robot 🤖decision making, let’s chat!
1
8
We revamped our IROS paper on refining Control Barrier Functions to emphasize how our algorithm, refineCBF, can be used by practitioners in safe learning (I also got to play around with graphical design⬇️). Go check it out and see you in Kyoto in October! arxiv.org/abs/2204.12507

Very excited to share that our work “Refining Control Barrier Functions through Hamilton-Jacobi Reachability” with @SylviaLHerbert was accepted to IROS 22 in Kyoto 🇯🇵. Check out the preprint arxiv.org/abs/2204.12507 and be on the lookout for follow up work soon.
Flying to New York🗽 tonight for #RSS2022 next week. Looking forward to my first in-person robotics conference! If you work on safety in robot control and decision making, let's chat 🤖
1
11
I'm particularly looking forward to the #RSS2022 workshops on Risk Aware Decision Making and Implicit Representations for Robotic Manipulation!
2
We show that we can update conservative CBFs, rendering the safety filter less invasive, while remaining safe!
We are particularly excited about leveraging this method on hardware (currently ongoing!) to adapt to sudden changes in the environment (3/n)
1
2
In addition, we can refine invalid CBFs to guarantee safety. We provide an open-source implementation github.com/UCSD-SASLab/refin…. Give it a try!
We also provide an intuitive CBF library in python: github.com/stonkens/cbf_opt
(4/n)
Sander Tonkens retweeted

🚨 New exciting work: Temporal Difference Learning for Model Predictive Control
nicklashansen.github.io/td-m…
We combine strengths of model-based (MPC) and model-free (TD-learning) RL. Result: a powerful algo that solves *challenging* control problems from state and pixels.
🧵👇 (1/n)
🎁🎄Little Christmas present to myself, finally got around to having the first draft of my personal website ready
Feel free to check it out and shoot me a message if you want to chat about research: sandertonkens.com
1
Excited to share: "Optimizing Vaccine Allocation Strategies in Pandemic Outbreaks: An Optimal Control Approach"
We investigate how to allocate multi-dose vaccines when responding to a pandemic outbreak, with a case study on the COVID-19 vaccination rollout in The Netherlands!
This Post is from an account that no longer exists. Learn more
7
I'm in the Bay Area this weekend and will also be at BARS on Friday. Looking forward to catching up in person (!) with friends from Stanford, Berkeley, and anywhere else!

Bay Area Robotics Symposium (BARS) will be happening in person this Friday on October 29!
The registration will close on October 27th, 5 p.m.
Register here: sto.stanfordtickets.org/bay-…
Program: bars-2021.github.io/

7
🙋I didn't know I was signing up for weekly downpours when moving to SoCal. Secretly loving it though!😍
(I do know it probably won't last...)

Who has been enjoying this weather? 🙋♀️ Here are the final rainfall totals for the past 48 hrs: go.usa.gov/xMwkP
If you're ready for more, you're in luck. Another round of widespread rain is expected at the end of the week. Forecast rainfall totals are below! #CAwx


1