

TinyNav: A lightweight, hackable system to guide your robots anywhere. by @dvorak0
Joined April 2025
- Tweets81
- Following149
- Followers50
- Likes13







UniflexAI retweeted

Insight 9 SLAM Robustness Test 🎥
We put our AI-native spatial camera through rapid, dynamic movements. Watch the right screen: TinyNav VSLAM trajectory in RVIZ stays perfectly stable. 24G accelerometer & 188° ultra-wide FOV = zero tracking loss.#SLAM #Robotics #EmbodiedAI #VSLAM
FoundationStereo >> FastFoundationStereo > Retinify

We expected FastFoundationStereo to be close to FoundationStereo. We were wrong.
On Jetson Orin Nano:
- FoundationStereo surprised us — lidar-quality point cloud
- FastFoundationStereo is far worse (yes, it is indeed fast)
- Retinify matches FastFoundationStereo's quality but is faster
Speed: 100ms vs 15ms.
Our fork fixed the 2-stage ONNX export with custom TensorRT plugins → single ONNX/plan.
Repo: github.com/UniflexAI/Fast-Fo…
cc @retinify @bowenwen_me

Just updated it to include frontend benchmarks. The first version compares Harris + Optical Flow with ORB + Hamming matching.
Keep watching: github.com/dvorak0/slambench
You can also easily reproduce the test with:
docker run --rm --cpuset-cpus="0" uniflexai/slambench:latest


Thanks for open-sourcing such great models. In our early test, Fast Foundation Stereo reached real-time performance (>13.5 FPS) with max disparity 64 on Jetson Orin NX — honestly much better than we expected.
We’re planning to integrate it into our open-source navigation stack soon:
github.com/UniflexAI/tinynav


🚀Our code is released: github.com/NVlabs/Fast-Found…
Enjoy!

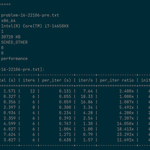
I’ve updated github.com/dvorak0/slambench with more benchmark results, including row-major vs column-major comparisons and GTSAM SmartFactor benchmarks.
Added a summary screenshot below — check it out!

Working on SLAM for years, I’m constantly asked: which method is faster?
So I made a one-line command to benchmark solver speed with the standard dubrovnik/problem-16-22106-pre.txt input:
`docker run --rm uniflexai/slambench:latest`
Run it, share your result, and tell me if anything looks unexpected.
cc @gtsam4 @SkydioHQ @sandwichmaker

UniflexAI retweeted
The wait is over. Meet Insight 9👁️
Native Spatial AI. 24g IMU. All packed in a Premium Aluminum Alloy Case.
We are redefining vision for Embodied AI. Coming exclusively to Kickstarter.
#SpatialAI #Robotics #Kickstarter #TechLeak #EmbodiedAI #TechNews #TechTrends
🚀 Introducing the TinyNav Bounty Program
We’re rewarding the community for contributions that improve navigation, perception, and tooling in physical AI.
🧠 Bug reports
🧩 Code contributions
📝 Docs & tutorials
🎥 Demos & content
Earn rewards while shaping the future of open robotics.
🔗 Details: docs.google.com/spreadsheets…
#TinyNav #Robotics #OpenSource #PhysicalAI
UniflexAI retweeted

Is it just me or are these robots getting TOO real? 🤖
Caught this @UnitreeRobotics dog zooming past. That new sensor rig looks like giant shades 🕶️. Scary smooth gait.
Is this a secret field test? 🤯🔥 #Robotics #Unitree #TechLeak #FutureIsHere #Spotted

saw completely new design of the head. @UnitreeRobotics is going to navigate the robots using stereo camera, just like our open source project tinynav github.com/UniflexAI/tinynav


Excited to share a video about the workflow of our project!
From zero to navigation with TinyNav 🗺️➡️🤖
1️⃣ Build a map
2️⃣ Add POIs in the editor
3️⃣ Let your robots navigate, correctly react to obstacles, and find feasible paths
Keep an eye on TinyNav — a ~3,000-line open-source navigation stack for multiple robot platforms 🚀
We’ve added a remote interface using @foxglove — an amazing tool. Thanks, Foxglove 🙌 #Robot #Unitree #navigation
We need re-consider our stereo model! I will report the difference soon in our project.
Cool! New player in the room.

Today we’re thrilled to announce #SharpaWave — our first dexterous robotic hand — now officially in mass production and delivery!
Robotic dexterity just took a leap forward.
#Sharpa #Robotics #AI #DexterousHand #Robot #Humanoid #TactileSensing