

AI || Integration Engineer || Software Engineer ||
CA, U.S.A.
Joined August 2010
- Tweets20.7K
- Following631
- Followers436
- Likes4.8K




Pamela Villalon retweeted

The part we've all been waiting for!!!!!!!
#MetaAIHackathon

Say hi to Physical MCP👋
SAM 3.1 + Muse Spark+ Muse Spark Open (Baseten) +human approves
Built in 9 days for the #MetaAIHackathon by @carelessluck & @bhavisha_ahuja
Would love for you to check out: physicalmcp.dev/
@AIatMeta @MetaforDevs @cerebral_valley @baseten
Pamela Villalon retweeted

We also built a site for you to try it out live: physicalmcp.dev/

Pamela Villalon retweeted
a kitchen timer, a webcam, two tiny servos and Meta’s models. that’s the whole rig. tonight you get to see it actually run
#MetaAIHackathon
I guess it's time you guys meet the rig
Stay tuned for the demo, will be posting it tonight
#MetaAIHackathon
Pamela Villalon retweeted
we gave a kitchen timer an API with a webcam and a $3 servo
what machine in your life should we try next?
Say hi to Physical MCP👋
SAM 3.1 + Muse Spark+ Muse Spark Open (Baseten) +human approves
Built in 9 days for the #MetaAIHackathon by @carelessluck & @bhavisha_ahuja
Would love for you to check out: physicalmcp.dev/
@AIatMeta @MetaforDevs @cerebral_valley @baseten
Pamela Villalon retweeted
so cool to see this here, thank you @raedle!! built this with @carelessluck <3
More coming soon!!!!!!!!
Pamela Villalon retweeted

🧵 (20/22)
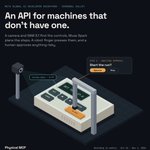
Physical MCP by @carelessluck is an API for machines that don't have one. A camera and SAM 3.1 find the controls, Muse Spark plans the action, and a robot finger presses the button.
teapawt.org/carelessluck/status/21…


Pamela Villalon retweeted
honored to be in this 🙏
a webcam, SAM 3.1, Muse Spark and a $3 servo. the AI asks a human before it presses anything risky
full demo dropping soon

🧵 (20/22)
Physical MCP by @carelessluck is an API for machines that don't have one. A camera and SAM 3.1 find the controls, Muse Spark plans the action, and a robot finger presses the button.
teapawt.org/carelessluck/status/21…
Pamela Villalon retweeted
Say hi to Physical MCP👋
SAM 3.1 + Muse Spark+ Muse Spark Open (Baseten) +human approves
Built in 9 days for the #MetaAIHackathon by @carelessluck & @bhavisha_ahuja
Would love for you to check out: physicalmcp.dev/
@AIatMeta @MetaforDevs @cerebral_valley @baseten
Pamela Villalon retweeted
fun fact: the hardest part wasn’t the AI, it was the timer. 250 ms presses didn’t register and 2 sec ones auto-repeated, so the finger holds for exactly 1 second
Pamela Villalon retweeted
I guess it's time you guys meet the rig
Stay tuned for the demo, will be posting it tonight
#MetaAIHackathon
Pamela Villalon retweeted
Moved the approval check into the press tool itself today.
The AI can plan whatever it wants. If a step is risky, the finger can’t move until a human holds down approve.
#MetaAIHackathon
Pamela Villalon retweeted
New rule in our build: anything that turns something ON has to be a press and hold. A tap won’t do it, even if the AI scores it low risk.
What’s a button in your life that should have needed a long press?
Pamela Villalon retweeted
Most machines in the world don’t have an API.
We gave one a finger.
Nov 4.
#MetaAIHackathon
Pamela Villalon retweeted
At @prof_oz’s Fireworks workshop for the Meta hackathon, one result stuck with me.
Muse Spark Open scored best at LOW reasoning effort (88.5). High effort dropped it to 81.8.
More thinking costs more and isn’t always better. Measure it per task.
Next up: our risk scorer.

Pamela Villalon retweeted
Same button. Same machine. Different risk.
START at 37 °C: medium
START at 90 °C: high, and you have to hold to approve
Muse Spark Open scores every step before our robot finger is allowed to press it

Pamela Villalon retweeted
This is us. Pam’s on the hardware and vision, Bhavi’s on the web app and approvals. First rule we agreed on: the finger doesn’t press anything risky until a human says yes. Updates daily from here.
Pamela Villalon retweeted
the plan for this week, in 3D.
two servos, one arm, and a pink fingertip that presses real buttons on a machine's control panel. next up is wiring the real parts and finding out how wrong the model is

Pamela Villalon retweeted
Most machines in labs and factories have buttons, a tiny screen, and no API.
This week we’re giving them one. A camera, an AI, and a robot finger that asks before it presses anything risky.
Building for the @MetaforDevs hackathon with @cerebral_valley

