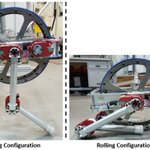
The Flyped robot features a hybrid design that combines wheels and legs for flexible movement, allowing agile bipedal walking in unstructured environments and efficient rolling on flat, structured terrain. biorobotics.ri.cmu.edu/robot…
3
61
Chao Cao,a Ph.D. student at the Robotics Institute,is focused on using autonomous robots to explore large, complex environments.His paper,"Representation granularity enables time-efficient autonomous exploration in large,complex worlds",can be found here science.org/doi/10.1126/scir….
1
51
Robo Spotlight: Julian Whitman was a postdoc focused on modular robot design and control synthesis. Check out his latest paper, "Learning Modular Robot Visual-motor Locomotion Policies", accepted to 2023 IEEE ICRA. tinyurl.com/JWICRA
2
129
The Exobiology Extant Life Surveyor (EELS) Project is developing a snake robot that can traverse the terrains of Saturn’s moon. Its goal is to search for liquid water, explore a wide variety of environments, and perhaps search for evidence of life. biorobotics.ri.cmu.edu/resea…

ALT “Team members from JPL tested a snake robot called EELS at a ski resort in the Southern California mountains in February. Designed to sense its environment, calculate risk, travel, and gather data without real-time human input, EELS could eventually explore destinations throughout the solar system.” Credit NASA/JPL-Caltech
1
43
Ramkumar Natarajan, a PHD student at the Robotics Institute, is focused on improving manipulation tasks of robots in close proximity to people. Check out his paper, "Torque-Limited Manipulation Planning through Contact", accepted to 2023 IEEE ICRA. biorobotics.ri.cmu.edu/paper…
1
94
The Hardened Underwater Modular Robot Snake (HUMRS) aims to inspect ships, submarines, underwater pipes, and more. Current work focuses on increasing autonomy to facilitate human operator control in turbulent environments. This video shows HUMRS going for a swim in CMU's pool.
3
38
Robo Spotlight: Zhongqiang (Richard) Ren is a postdoc focusing on solving fundamental path and motion planning. Check out his latest paper, "Search Algorithms for Teamwise Cooperative Multi-Agent Path Finding", accepted to 2023 IEEE ICRA. tinyurl.com/ZRICRA
3
39
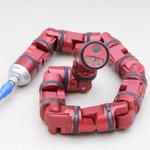
Our iconic modular snake robots are ideal for navigating tough terrains and hard to explore locations. Due to their internal degrees of freedom, they can perform locomotion capabilities that go beyond that of wheeled and legged robots.
biorobotics.ri.cmu.edu/robot…
3
37