

Humanoids that care. Creators of OpenArm: https://xitter.cf/t.co/s1S7X8KiTD
Tokyo, Japan
Joined July 2025
- Tweets84
- Following3
- Followers2.7K
- Likes35




Pinned Tweet
After a long wait since our last announcement, OpenArm 2.0 is finally here.
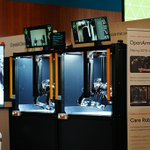
We're expanding from a robotic arm into a standard evaluation environment for Physical AI research, anchored by OpenArm Cell.
- OpenArm Cell for reproducible eval
- New pinch-type end effector
- Standardized cameras
- Redesigned J5 wrist (natural teleop)
- VR teleop
- Long-term stable release
github.com/enactic/openarm

Enactic retweeted

#ROSCONCN
日本から @enactic @gunyarakun のシェア。
Senna, groongaといった #ニコニコ動画 を支えたOSSの検索ソフトを作っていたメンバーが #Openarm の中核にあり
#bilibili にたくさん活用事例が上がるオープンなハードウェアになった
素晴らしい @nojiri_h @iyokan_nico #rosjp


We opened an issue asking for a LeRobot gym env, and Niklas Kleiser built it!
gym_openarmv2: a Gymnasium env for the OpenArm v2 Cell with lerobot-eval support. Evaluate our ACT policy on the pick-and-place task in MuJoCo with one command.
github.com/xXFiEsTaDeAmOnXx/…
#OpenArm
The policy and dataset it evaluates against:
ACT policy: huggingface.co/enactic/act-o…
Dataset: huggingface.co/datasets/enac…

gym_openarmv2 vendors the OpenArm v2 Cell assets from openarm_mujoco and follows the gym-aloha layout, so lerobot-eval drives it like pusht or aloha.
The original request and Niklas's comment that closed it:
github.com/enactic/openarm/i…


Enacticの取り組みを紹介した「テレビ東京「アンパラレルド〜ニッポン発、世界へ〜」ですが、TVerにて2026年9月9日(水)23:54まで視聴可能です。
tver.jp/episodes/epykxq7pts

【2026/8/10(月) 19:00】
第7回OpenArm勉強会を開催します🦾
オープンソースのロボットアームOpenArm 2.0、それを核とした評価環境Cell、遠隔操作デバイスKERのリリース後初の勉強会は、秋葉原会場とオンラインのハイブリッド開催。
ぜひご参加を!
open-arm.connpass.com/event/…
#OpenArm #ロボットアーム

We are excited to announce the release of a new OpenArm teleoperation device: KER (Kinematic Equivalent Replica). This is a lightweight leader device that shares the exact same joint structure as OpenArm 2.0.
KER uses only encoders for each joint, no motors, allowing for smooth and easy operation with zero resistance. Every joint maps 1:1 to OpenArm 2.0, so no coordinate transforms are needed.
This release marks the completion of the OpenArm 2.0 ecosystem. KER, OpenArm, and the Cell are all open source and are ready to be used in state-of-the-art reproducible research! 🦾
#OpenArm #OpenSource #Robotics


Dig in:
GitHub: github.com/enactic/openarm
KER docs: docs.openarm.dev/hardware/op…
What's new in OpenArm 2.0: docs.openarm.dev/overview/wh…
Arm, Cell, KER. All yours.

NVIDIA GR00T N1.7の介護領域における日本初の実用性検証を開始しました
prtimes.jp/main/html/rd/p/00…
Enactic retweeted

【📣プレスリリース】
#FastLabel がOSS公開したロボットデータ収集/品質解析アプリ「#OpenLUTRA」が、#Enactic 社「#OpenArm 2.0」に対応しました!
👉詳細はこちら:
prtimes.jp/main/html/rd/p/00…

Enactic retweeted
After a long wait since our last announcement, OpenArm 2.0 is finally here.
We're expanding from a robotic arm into a standard evaluation environment for Physical AI research, anchored by OpenArm Cell.
- OpenArm Cell for reproducible eval
- New pinch-type end effector
- Standardized cameras
- Redesigned J5 wrist (natural teleop)
- VR teleop
- Long-term stable release
github.com/enactic/openarm
OpenArm 2.0 is now shipping from WowRobo, starting at $6,500. V1→V2 upgrade kit from $1,080.
OpenArm Cell (from $6,200): A workspace with 300mm Z-axis, top camera, and lighting for reproducible embodied AI.
docs.openarm.dev/purchase/


How do we make robot policy evaluation reproducible across labs?
Announcing OpenArm 02:
a fully open-source dual arm platform, with a unified setup for reproducible evaluation: controlled tasks, backgrounds, lighting, and camera angles.
✅ Fully open-source, so anyone can replicate the setup anywhere
✅ AutoEval: 24/7 real-world evaluation with minimal human intervention (building on work by @zhiyuan_zhou_)
✅ Fair side-by-side policy comparison
OpenArm is the open foundation to turn isolated results into shared progress.
Releasing soon. Stay tuned.
The @dimensionalOS team is adding OpenArm integration to their open-source robotics platform. Try pick & place, teleop, and RRT planning with OpenArm.
It's a work-in-progress feature branch and they're looking for early feedback.
github.com/enactic/openarm/d…

Enactic retweeted

昨年12月に新設されたRoboticsチームより、初のデモ映像をお届けします✨
自社カスタマイズしたOpenArm8台を用いてデータ収集し、E2Eモデルを訓練しました。
まずは目標としていた自律でのTシャツ折りたたみの基本動作を実現しました。
#SBIntuitions
Enactic retweeted

Folding clothes with #OpenArm
Great work by @pepijn2233 and the @huggingface team. Looking forward to more collaboration!

Releasing the Unfolding Robotics blog!
Time to unfold robotics: we trained a robot to fold clothes using 8 bimanual setups, 100+ hours of demonstrations, and 5k+ GPU hours.
Flashy robot demos are everywhere. But you rarely see the real story: the data, the failures, the engineering.
We’re sharing everything: code, data, and details in the blog → huggingface.co/spaces/lerobo…