




Pinned Tweet
Excited to share our paper "SonicBoom" was accepted to RA-L and featured in IEEE Spectrum! 🎉
We propose a novel way to sensorize a robot arm using sound — localizing contact by listening with a microphone array. 🦾🔊
📰 Article: spectrum.ieee.org/farm-robot…
🧵👇

I'm at #CoRL and #Humanoids, and looking for full-time job positions. I'd love to connect and discuss opportunities!
Presenting:
1️⃣ SonicBoom: Contact Localization Using Array of Microphones
Featured in IEEE Spectrum, (Tues) TI4C.6, 2PM
2️⃣ Audio-Visual Contact Classification for Tree Structures
(Wed) WI2C.10, 10AM
2️⃣ Audio-Visual Contact Classification for Tree Structures:
We gave farm robots the ability to sense contact by fusing sound with vision, making agriculture tasks safer and smarter.
Project Page: tree-classification.vercel.a…

1️⃣ SonicBoom:
We propose a novel way to sensorize a robot arm using sound — localizing contact by listening with a microphone array.
Project page: iamlab-cmu.github.io/sonicbo…
💡 Key insight: The way we represent audio matters. Using a spectrogram often leads to overfitting. Instead, explicitly encoding phase information between microphone pairs significantly improved generalization to new surfaces like plastic or aluminum, when trained only on wood.
For more info, check out:
Website: iamlab-cmu.github.io/sonicbo…
Paper: ieeexplore.ieee.org/document…
Mark Moonyoung Lee retweeted

🤖📦 Want to move many items FAST with your robot? Use a tray. But at high speeds, objects may fall off 💥.
Introducing our new method: it hears sliding 🎧, learns dynamic friction 🥌, and plans time-optimized motions to transport objects 🚀.
fast-non-prehensile.github.i…
🧵1/7
Really exciting work to use audio-visual signals in agriculture settings for more contact-aware manipulation! @dorryspears @iamlab_cmu

Very excited to share what @make_your_maark and I have been working on! We gave farm robots the ability to sense contact by fusing sound with vision, making agriculture tasks safer and smarter.
🧵1/8
Mark Moonyoung Lee retweeted

Very excited to share what @make_your_maark and I have been working on! We gave farm robots the ability to sense contact by fusing sound with vision, making agriculture tasks safer and smarter.
🧵1/8
Mark Moonyoung Lee retweeted

🤖We are introducing Grounded Task Axes (GTA) — a zero-shot skill transfer framework that enables robots to perform multi-step manipulation tasks on novel objects by generalizing modular controllers grounded through visual foundation models.
✅ No training, no demo, no finetuning — just zero-shot
🔧 Modular task-axis controllers
🎯 Grounded via visual foundation models
🧠 Generalizes across tools & objects
🥄🍳☕🔩 Scraping, pouring, screwing, insertion
Find more about our paper:
🌐 iamlab-cmu.github.io/GTA/
📄 arxiv.org/abs/2505.11680

🔊🦾 RoboAcoustics: Workshop on Acoustic Sensing and Representations for Robotics at ICRA 2025.
We have amazing speakers lined up! If you are at ICRA (or on Zoom), check out our workshop 5/19 Mon 9am-5pm in Room316!
Workshop Website: sites.google.com/view/roboac…

Will be at #ICRA2025 🦾 presenting 2 works:
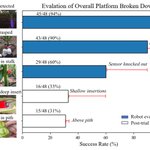
1. Towards Autonomous Crop Monitoring: Inserting Sensors in Cluttered Environments
📍05/22 4:35pm Room408 (from RA-L).
2. SonicBoom: Contact Localization with Microphones
📍05/19 2:30pm Room316 - workshop (recent RA-L submit).


Website for 1st work on crop monitor robot 🌽: kantor-lab.github.io/cornbot…
Website for 2nd work on sound localization 🔊: iamlab-cmu.github.io/sonicbo…
Mark Moonyoung Lee retweeted

Excited to share that our paper, "Multi-Robot Motion Planning with Diffusion Models," has been selected for a Spotlight presentation at #ICLR2025!🔦🤖
We scale diffusion planning to dozens of robots *without* multi-robot data by using search.
Project: multi-robot-diffusion.github… 🧵
Mark Moonyoung Lee retweeted

Can 3D scene graphs act as effective online memory for solving EQA tasks in⚡️real-time?
Presenting GraphEQA🤖, a framework for grounding Vision Language Models using multimodal memory for real-time embodied question answering.
Mark Moonyoung Lee retweeted

CMU covered our work on the Robotics Institute website!

Check out CMU’s collab with Meta in Science Robotics!
Congrats to 2024 Ph.D. graduate Sudharshan Suresh and Professor Michael Kaess for their incredible work!
Read more about the project: ri.cmu.edu/cmu-and-partners-…

Mark Moonyoung Lee retweeted

1/ 🎉 How can we develop methods to generate synthetic, photorealistic data for training #AI models in robotics? We present SplatSim, a step in this direction. SplatSim is a scalable framework that generates photorealistic data for manipulation tasks using existing simulators as a physics backbone — enabling zero-shot Sim2Real policy transfer for RGB policies! 🌍
Check out our project page: splatsim.github.io and paper on arXiv arxiv.org/abs/2409.10161
With @_sparshgarg_ Francisco Yandun, @davheld, George Kantor, @abhi_silwal
@CMU_Robotics