

working from zero to humanoid.
Joined April 2026
- Tweets106
- Following107
- Followers34
- Likes160






Hey @Hash_hopes & @prismassets team.
Its absolutely ridiculous and irritating to see all the hate and paid fud (I have Proof) been directed towards you for no proper reasons (its only racism now)
I know you guys built robinhood:0x20024e485c0b22b42855589700721b28320a7777 genuinely for the past 3 months without a single day off or rest even when you were in hospital and as a chain analyst i know that theres nothing wrong except for people buying and selling normally and the price action is majorly affected by the market.
I personally hold a huge bag of robinhood:0x20024e485c0b22b42855589700721b28320a7777 when it was at 30K pre bonding till here and i have see and know everything and also know that you guys did your best and there was no fault from your end.
But i think its time to end the project because theres no need for you guys to take all this hate and torture even if you guys did nothing wrong.
I know how bad it can effect your mental health and i also know what kind of mental and physical trauma its gonna give you once the chain dies but only you will be targeted by the entire CT (they wont hate robinhood:0xe8ffd7e24187f72afb08d75b1bb13088a989a791, $INDEX or even the projects that rugged and made $18M)
They all love them because they are not Indian. But you are Indian and its your fault and no matter how much you work hard or plan things or be genuine, they wont let Prism go up ever. (They will attach a racist tag and people will forever be scared)
And these guys belonging to the same group and the fud is mainly orchestrated.
So please consider this my genuine advice and end the project.
Theres no reason for you to continue working and There is no point of trying to build something on a dead chain.
These guys think they are cool because they talk shit and throw racism, But its actually mentally retarded.
So let these people get ass fucked on their own and you dont need validation from anyone anymore and you did your best.
Please take my advice otherwise you gonna suffer soon.
Thank you,
Ogtose
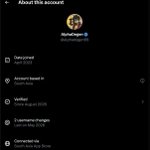
Exposing @alphadegen69 (Hes from Karachi, Pakistan which is the central hub for Islamic terrorism)
First he starts spreading negativity, absolute bullshit and hate towards solid crypto projects on a daily basis.
Then he proceeds to threaten developers to expose their private information and death threats which is against X rules @X @premium
I first saw this guy spreading hate against robinhood:0x20024e485c0b22b42855589700721b28320a7777 at 2M and then @prismassets went to 25M and dumped to 2.5M as market is bad.
This guy starts spreading hate, racism and absolute nonsense while asking people to skin the developer on X.
He and few of other Nigerian and Pakistani accounts start a co ordinated fud around the project and their reason for doing it is "The dev is Indian"
No accountability, no proof, no other reasons.
Just ethnicity.
From spreading misinformation and fake news to death threats, they never stop.
Meanwhile he goes on shilling his 30k shitter and rugs them from sides.
I tried reporting him in the past as he doesnt care about the gender and keeps on going talking nonsense and inappropriate stuff to women aswell.
This guy is an absolute larp and i did some research on him and figured out he has blackmailed multiple developers and KOLs in the past for money aswell.
@X you need to take these matters seriously as this is against X rules and theres a lot of money involved!


Its really crazy how few Pakistani and Nigerian accounts trying to spread a co ordinated fud around robinhood:0x20024e485c0b22b42855589700721b28320a7777 .@prismassets
I have been in Prism since day-01 (since 31K) and i have been watching everything as this is one of my biggest bags.
And the way they are spreading baseless hate and abuse just proves whats real and whats not.
These guys are doing the same thing for every project out there while shilling their Pakistani shitters and rugging them for 30K.
I have been rugged in the past by this Alpha Degen guy and he trying to fud a 3 month old project is fucking ridiculous.
These guys have no idea of tek, no idea whats tokenized stocks and you can see that.
Dont listen to all this bullshit because there are more than 100 people from first day who are still here in robinhood:0x20024e485c0b22b42855589700721b28320a7777 and they know whats true and whats not.
Pathetic fud honestly


og.tose.ai retweeted

ngl you just explained the entire sim-to-real gap better than most PhD theses i've read. contact dynamics is where dreams go to die
og.tose.ai retweeted

Huge if true.
Rumor is that Anthropic is in talks to acquire Physical Intelligence.
While Google DeepMind has been actively developing Gemini Robotics and OpenAI has been quietly building a dedicated robotics team for over a year, Anthropic has shown almost no public signs of entering the physical intelligence arena.
If confirmed, this acquisition would give Anthropic an immediate and powerful entry into the robotics and embodied AI space.
Physical Intelligence is widely regarded as one of the most promising startups in embodied AI, known for its strong focus on scalable, general-purpose robotic intelligence and high-caliber research team.


Rumor from @dimensionalos’s open house. It makes an American OS for Chinese robots.
Was told that @AnthropicAI is buying @physical_int but deal hasn’t closed yet. That was from an investor.
San Francisco robot parties are fun. Hope you are having fun.
Now the nerds are playing robot soccer.

Congratulations Sunday Robotics for hitting 1,000 Memory Developers Milestone for ACT-2 Laundry Breakthrough
@sundayrobotics @tonyzzhao @chichengcc @perryzjia
great job onboarding masses to the new era of humanoids

day 41: zero to humanoid
40 days of going deep left me with a map of five unsolved problems : actuators, hands, data, sim2real, power.
i can't solve them that easily. honestly no single company can.
but the knowledge to attack them is scattered across arxiv, discords, teardown videos and tribal lab knowledge. that's the gap i can close.
so the first thing humanoids one ships: the wiki. one structured knowledge base for humanoid robotics. every actuator tradeoff, every sim2real trick, every hand design that failed and the reason why.
starting with the actuator section tonight.

a thought on improved learning memory for humanoids
xitter.cf/ogtose/status/20781067…

i think the real direction is combining hierarchical maps, gaussian splatting, keyframe-based slam, and learned memory compression.
robots don't need to remember every frame tbh, they just need to remember what matters.
that's probably how we get persistent 3d world models running efficiently on edge devices.
honestly the reconstruction accuracy thing was always a bit of a proxy
what matters for control is how the latent space is structured around actions. nice to see this proven on real hardware instead of sim benchmarks for once hahah

A new paradigm for robot learning that unifies latent world modeling and action generation.
Astribot has introduced Lumo-2, a latent world-action model for robot control.
- Validated on a real robot through 20+ intricate chores, extending beyond simple benchmark testing.
- A 3-stage recipe that progressively aligns actions with world dynamics, then vision, then language
- Action quality depends on the geometry of the latent space, not just reconstruction accuracy
- BAR (block-wise decoding) speeds up inference by 2.71x compared to standard autoregressive decoding
- Shows cross-embodiment transfer without specialized transfer learning
Results:
- Beats π0.5 and Fast-WAM in temporal reasoning, physical understanding, long-horizon, and dexterous manipulation
- Lumo-2's VLM consistently outperforms Qwen-3.5 4B on embodied benchmarks
llms needed the entire internet to generalize butthis needed just one clear out example.
robotics is about to move faster than anyone is pricing in.
physical intelligence just had its few shot moment.
love this ngl
the attached clip is how this one model can generalise 100 different behaviours

day 40: from zero to humanoid
went dark for 40 days.
spent all of it going deep into humanoid robotics and understanding how all of this actually works now and how it needs to work for much efficient outputs.
here's what i figured out. (some key takeaways, not all)
• the bottleneck isn't ai. it's actuators. everyone's obsessed with the brain but torque density is the real war. quasi-direct drive gives you back-drivability and impact tolerance, harmonic drives give you precision but explode on falls. every company is quietly making a different bet here and it defines their whole robot.
• hands are 50% of the problem. a humanoid body is around 30 degrees of freedom. one human hand is 27. tendon-driven hands wear out in weeks, linkage hands can't do fine manipulation. nobody has solved dexterity + durability + cost at the same time. whoever does wins general-purpose robotics.
• sim2real is a leaky abstraction. you can train locomotion in isaac gym in hours, but contact dynamics, cable friction, and motor thermals don't transfer. domain randomization papers over it. the gap between "walks in sim" and "walks in your kitchen" is where 90% of engineering time goes.
• the data problem is worse than anyone admits. llms had the internet. humanoids have nothing. teleoperation gets you demos at ~$X/hour of human time, and you need millions of hours. this is why everyone's fighting over VLA architectures and they're trying to steal generalisation from vision-language models because robot data doesn't exist.
• thermals are a silent killer. a humanoid standing still is burning power just fighting gravity. knee and hip motors saturate thermally in minutes under load. this is why demo videos are short. battery is 1-2 hours real-world, and adding battery adds mass which needs more torque which needs more battery.
• whole-body control is having an identity crisis. classical MPC is precise but brittle. end-to-end RL is robust but unexplainable. the frontier is hybrid and RL for locomotion, model-based for manipulation and nobody agrees where the seam should be.
the takeaway: this industry needs shared knowledge infrastructure more than it needs another robot company tbh
that's what i'm building. more soon.
day 0 update: from zero to humanoid
started sketching the architecture today.
what started as a humanoid robotics platform is quickly turning into a collection of 8 major systems:
• humanoid wiki
• troubleshooting terminal
• build guides
• skill marketplace
• ai agent swarm
• 3d body designer
• agent finance layer
• robotics training data marketplace
the funny part is that each one could probably be its own company.
but the whole point is that they shouldn't be separate.
building a humanoid robot requires knowledge, design, simulation, troubleshooting, training, deployment, and capital.
all of it needs to live in one place.
still early. still just boxes and arrows.
but it's starting to look real.
yeah im serious now.
im going to build an all in one terminal for humanoids and robots.
idk where to start yet.
but im gonna do it
loops give you depth, moe gives you capacity, and you basically get adaptive compute thrown in
wow sick build

Introducing OpenMythos
An open-source, first-principles theoretical reconstruction of Claude Mythos, implemented in PyTorch.
The architecture instantiates a looped transformer with a Mixture-of-Experts (MoE) routing mechanism, enabling iterative depth via weight sharing and conditional computation across experts.
My implementation explores the hypothesis that recursive application of a fixed parameterized block, coupled with sparse expert activation, can yield improved efficiency–performance tradeoffs and emergent multi-step reasoning.
Learn more ⬇️🧵
