


Pinned Tweet
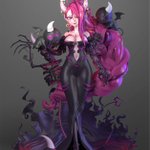
#cottonart Figurine fanart. I debated finishing this one after seeing her excellent official 3D model but I had this about 80% done when that debuted so I figured might as well. I like the design a lot. More pics on my artstation.


Jhambi retweeted

We are back. After one year of quiet building.
Introducing GENE-26.5, our first robotic brain that takes a major step toward human-level capability.
For years, robotics has struggled to learn from the world’s largest and valuable data source: Humans.
Solving it means rethinking the whole stack from the ground up:
- A robotics-native foundation model.
- A 1:1 human-like robotic hand.
- A noninvasive data collection glove for motion, force, and touch.
- A simulator that turns weeks of experiments into minutes.
GENE-26.5 is trained across language, vision, proprioception, tactile, and action. We designed a set of tasks to test how far we can go with this new paradigm.
Fully autonomous, 1x speed, one model, same weights. (Enjoy with sound on)
We are approaching the endgame for robotics.
And this is just a beginning.


Jhambi retweeted

Self-improvement 🔄
SIMA 2 can teach itself new skills, learning through trial-and-error, based on feedback from Gemini. Getting better the more it plays – without additional human input.


This is nuts. Knowing that it can work from existing video is interesting too, from the standpoint of eventually being able to generate a custom version of an existing movie/show in real time or interactively hopping into a scene.

Something we discovered by accident: what happens if we start Genie 3 from a video and a completely unrelated prompt? Turns out the model really, really wants to make it work, to the point where it emulates itself.
The prompt in this one is about a trex on a tropical island.
322
Jhambi retweeted
What if you could not only watch a generated video, but explore it too? 🌐
Genie 3 is our groundbreaking world model that creates interactive, playable environments from a single text prompt.
From photorealistic landscapes to fantasy realms, the possibilities are endless. 🧵
Jhambi retweeted

On IMO P6 (without going into too much detail about our setup), the model "knew" it didn't have a correct solution. The model knowing when it didn't know was one of the early signs of life that made us excited about the underlying research direction!


Friendly reminder that good AI image gen is now basically indistinguishable from real. People claiming 'they always know' while looking for the mushy detail or mutant hands of old tech need to update their mental model. Video will likely be there by year end. Trust accordingly.


1
271
Jhambi retweeted
Atlas is demonstrating reinforcement learning policies developed using a motion capture suit. This demonstration was developed in partnership with Boston Dynamics and @rai_inst.
Blender makes sense for something like this, given how open/documented it is and everything being controllable through the console that Claude can hook directly into. I wonder how many more versions before Claude can retopo a zbrush sculpt better than me lol

Blender MCP is here, allowing Claude to talk directly to Blender. For example, provide a 2D reference image and ask Claude to create it in 3D for you.
268
Jhambi retweeted

Watch Firefly land on the Moon! After identifying surface hazards and selecting a safe landing site, #BlueGhost landed directly over the target in Mare Crisium. A historic moment on March 2 we'll never forget. We have Moon dust on our boots! #BGM1


Jhambi retweeted
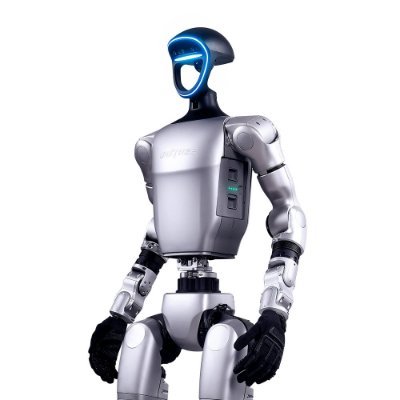
Unitree G1 Bionic: Agile Upgrade 🥰
Unitree rolls out frequent updates nearly every month. This time, we present to you the smoothest walking and humanoid running in the world. We hope you like it.
#Unitree #AGI #EmbodiedAI #AI #Humanoid #Bipedal #WorldModel
Jhambi retweeted

This is a single uncut video, showing a robot learning several tasks instantly, after just one demonstration each ...
This is possible because we've now been able to achieve in-context learning for everyday robotics tasks, and I'm very excited to announce our latest paper:
🎆 Instant Policy: In-Context Imitation Learning via Graph Diffusion 🎆
robot-learning.uk/instant-po…
(1/6) 🧵👇
Jhambi retweeted

#UNITREE #ROBOTDOG #QuadrupedRobot
Unitree B2W Wheeled Robot Dog Robust platform fearlessly dives from near 5-meter-high slide, climbs back to high platform. While carrying hefty 35Kg. Impeccable blend of explosive power and unwavering stability even in muddy conditions.
Jhambi retweeted

Not every foundation model needs to be gigantic. We trained a 1.5M-parameter neural network to control the body of a humanoid robot. It takes a lot of subconscious processing for us humans to walk, maintain balance, and maneuver our arms and legs into desired positions. We capture this “subconsciousness” in HOVER, a single model that learns how to coordinate the motors of a humanoid robot to support locomotion and manipulation.
We trained HOVER in NVIDIA Isaac, a GPU-powered simulation suite that accelerates physics by 10,000x faster than real time. To put the number in perspective, the robots undergo 1 year of intense training in a virtual “dojo”, but take only ~50 minutes of wall clock time on one GPU card. The neural net then transfers zero-shot to the real world without finetuning.
HOVER can be *prompted* for various types of high-level motion instructions that we call “control modes”. To name a few:
- Head and hand poses: can be captured by XR devices like Apple Vision Pro.
- Whole-body poses: via MoCap or RGB camera.
- Whole-body joint angles: Exoskeleton.
- Root velocity command: Joysticks.
What HOVER enables:
- A unified interface for us to control the robot using whichever input devices are convenient at hand.
- An easier way to collect whole-body teleoperation data for training.
- An upstream Vision-Language-Action model to provide motion instructions, which HOVER translates to low-level motor signals at high frequency.
HOVER supports any humanoid that can be simulated in Isaac. Bring your own robot, and watch it come to life!
It's a big teamwork from NVIDIA GEAR Lab and collaborators: 🧵