




Pinned Tweet
I built RoboRank: "It's like Leetcode for roboticists"
- On Leetcode you learn how to reverse a doubly linked list
- RoboRank teaches you to debug control systems, implement filters, and use powerful tools like @rerundotio to debug simulations. All scored on a global leaderboard
Ben C retweeted

wow @jacobvm04 and i just took first place on one of robotics’ hardest problems.
machines knowing where they are in the world.
slam dunk.

ALT sota
Ben C retweeted

when LaMAria was introduced a year ago, Meta's closed-source Aria SLAM was far ahead of academic systems.
one year later, we've surpassed it in 3/5 categories: medium, long, and low light.
here's what closing that gap looks like:

wow @jacobvm04 and i just took first place on one of robotics’ hardest problems.
machines knowing where they are in the world.
slam dunk.
ALT sota


Ben C retweeted

We raised a $10M seed for @Robocurve, an independent Public Benefit Corporation, to evaluate frontier AI in the physical world.
In less than 3 months, our research has been viewed 6M+ times and our evaluation harness downloaded 97k+ times. Researchers from 200+ institutions, including 19 of the world’s top 20 universities, have signed up to build benchmarks with us.
We welcome more independent evaluators. The more third-party evaluators, the better society can understand how fast robotics AI is progressing. Our evaluation harness is fully open-source, and we publish benchmarks anyone can run and verify.
Our round is led by @Initialized, with participation from @notablecap, @decasonic, @ycombinator, @HalcyonFutures, and many others.
Building robots or frontier AI? Work with us to help the world understand what your systems can do.

ALT Robocurve seed funding announcement. Cream text on a darkened photograph reads: “Robocurve. $10M. Seed funding. Independent evaluation of frontier AI in the physical world.” On the right is a close-up of a robot gripper with a mounted camera.
Ben C retweeted

GPT-Live-1 is now available in the API.
Bring ChatGPT’s natural back-and-forth to your app, with voice agents that listen while they speak and work with the models and harness you choose.
Ben C retweeted

Rowve doesn’t have a website.
We don’t have a deck.
We don’t even have a logo.
But we do have a prototype, our first customer, and now VC backing!
Excited to share that @deepwatermgmt has invested in Rowve as we build and validate the next generation of agricultural robotics

Ben C retweeted
One question that's been on my mind for years now is: could we use regular multimodal LLMs not necessarily trained for robotics to do the high level robotics intelligence part that VLAs and WAMs attempt to do?
The latest explosion of powerful opensource multi-modal LLMs has, IMO, begun to make this possible due both to intelligence and speed.
This is GLM 5.3 Flash, which has vision understanding, but isn't meant to be a VLA/VLM/WAM/robotics model at all, controlling an XGO mini wheeled robot quadruped with an arm & gripper.
GLM 5.3F simply has access to the robot's high level SDK for controlling movement, arm joints, open/close gripper...etc. It analyzes the frames from the camera and makes adjustments all on its own to solve the task.
Nothing was trained here, nothing fine-tuned for this task. Z AI did not make this model for robots and tbh I think they're surprised this works when I talk to them about it!
This also works quite well with DSV4F + a vision capable model like Qwen 3.8 27B. I havent tried JUST Qwen 3.8 27B, but I'm sure it works too. I like the "logic" to be a model that's as fast as possible (but still intelligent). There's also an experimental vision version of DSV4F, I'm confident that'll work too and might even be better bc the full loop might be the fastest of all with this model.
An obvious question you might wonder is: well why not use VLA or VLM? The hard part about robotics isn't object detection, that's long solved. This also isn't a solution for gait/locomotion...yet, but I actually don't think this is far away either and I've done some experimentation with LLMs in this space in the past and it does show promise.
It might actually already be here for quadrupeds, since you dont need super fast IMU readings to maintain balance. I've also tried many of the larger, more generalist, VLAs that you should be able to use with popular robots and tbh there are just so many edge cases that make things hard and not work. You gotta get the camera, lighting, task, everything *just right* or the demo fails.
This is for the actual hard part in robotics right now: intelligence, logic, and planning for all the ways the real world just simply isn't perfect.
I've trained VLAs. They're super finicky and you're always running into sim2real issues, especially around the camera. You also have to build the whole training pipeline in a simulator, and, if everything does work, you still just have a robot that does this 1 single thing after weeks of work.
If you use teleop, this overcomes the "2real" problem, but now you need to painstakingly collect teleop data, and it's only good at that specific task and that particular robot. There is a growing set of egocentric training data for "general purpose" VLAs and world action models (for humanoid form factors), but I'm really starting to wonder: Why? I think we might just sidestep this whole area of research entirely.
I didn't need any training data or special environment to work with this quadruped and arm to do the task I was after. This particular quadruped and arm doesn't even exist in the wild yet really, it's a demo build from a company launching it on kickstarter, so it's not like this robot's data exists in the LLM to any real extent.
I think this is cool as heck that this works and I am interested to see just how far I can push it.
Also this marks the first time that I've finally got a generalist solution to a task I've been trying to solve ever since I became a dad of twins: pick up toys off the ground. This is a big day!
Ben C retweeted

SITUATION DETECTED: The US government has sided with OpenAI against the New York Times. The DoJ says training an LLM on copyrighted works does not violate copyright law, and that treating it as infringement would hurt US science, prosperity, and national security.
Ben C retweeted
The last 72 hours since I posted this have been insane.
I’ve already received over 75% of the original $25K angel target, with additional commitments of up to $50K!
This would seriously change what I can build over the next 3 months.
I was originally planning incremental improvements for v2.
Now I’m evaluating a much more ambitious bimanual, over-row platform: two robotic arms working directly over the crop, with modular tooling designed to support tasks like weeding, planting, pruning, and harvesting.
This is much closer to the full Rowve vision:
A general-purpose physical intelligence platform for field labor.
I’ve also received inbound interest from both accelerators and institutional investors!
This week I’m focused on closing the angel round, recruiting the right technical team, and locking in the plan for what we build next.
Huge thank you to the early Rowve investors so far, including @BdcauntBen @CosmicDude3000 @liveforeverandb, along with several others who preferred to remain anonymous.
Let’s build 🦾

The next 3 months of Rowve starts now. 🌱
I put together a $25K plan for angel investors fund this next phase, breaking down exactly where the money goes in this video.
The plan:
→ Build and integrate V2
→ Develop modular mechanical weeding tools
→ Start field + autonomy testing
→ Sign 2 additional growers for next season
→ Use that technical progress + customer traction for pre-seed
Time to build 🦾
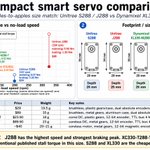
Exciting to see more competition in the serial servo space!


Microduck is a really fun robot. We highly recommend giving our brushless digital servo a try. 🥰🥰unitree.com/DigitalServo
Readers added context they thought people might want to know
Microduck is not using Unitree's Servo.
x.com/matth_lapeyre/…
Ben C retweeted

Agentic code review at WarmHub, by the numbers: 1,000+ reviews in 30 days, median under 2 minutes, under $3 a PR, routed by risk. Every finding verified against the code before it posts.
The full breakdown → warmhub.ai/blog/asserting-co…
